Robotized and automated warehouse systems
A robot may not injure a human being or, through inaction, allow a human being to come to harm. Three Laws of Robotics - Isaac Asimov
🧠 Learning objectives
- Discuss the rationale for automation.
- Identify and classify different types of warehouse automation technology.
- Analyze the adequacy of automation technology for different scenarios.
Why automation?
- Potential savings:
- Space;
- Labor cost (high employee turnover);
- Operational costs (e.g., heating and lighting).
- 24/7 availability.
- Scalability and throughput flexibility.
Caveat: Automation of storage and order picking requires considerable scale and a long-term vision, as the investments can be earned back only in the medium and longer term Azadeh et al. (2019)
Dark warehouses
Material flow in a typical automated warehouse
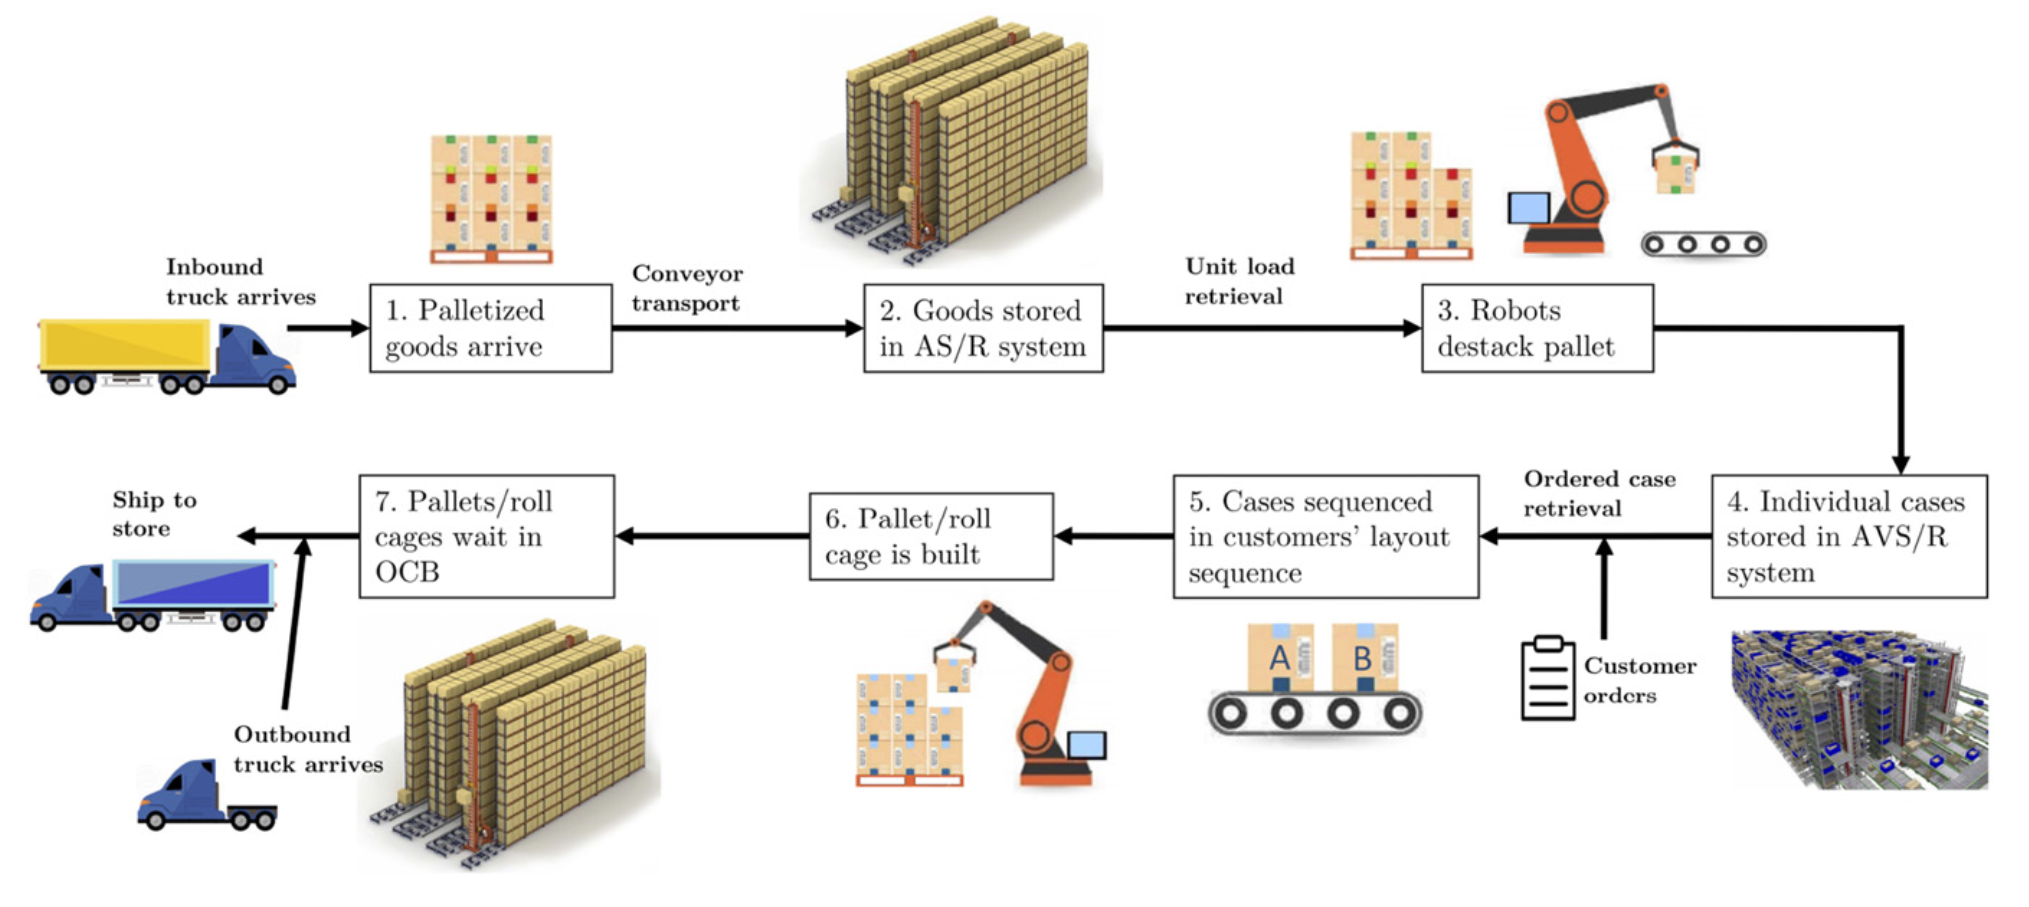
Classification of automated picking systems
Automated picking systems
Shuttle (AVS/R)
- A shuttle is sometimes referred to as an automated guided vehicle (AGV) or robot.
- Shuttle-based storage and retrieval system = autonomous vehicle-based storage and retrieval (AVS/R).
- Types:
- Aisle-based shuttle systems.
- Grid-based shuttle systems.
Automated picking systems: Shuttle (AVS/R)
Aisle-based shuttle systems
- Throughput capacity of AS/R systems is constrained:
- One crane handles loads at all vertical levels within a given storage aisle.
- Autonomous vehicle–based storage and retrieval (AVS/R) systems:
- require investment similar to AS/R systems,
- offer a much higher retrieval capacity than AS/RS, and
- are more flexible in capacity (easy to add or remove shuttles).
- AVS/RS classification based on shuttles’ movement capability:
- horizontal,
- vertical, and
- diagonal.
Automated picking: Aisle-based shuttle systems
Single/Double-deep storage
- Shuttles can reach loads in one- and two-deep lanes.
Automated picking: Aisle-based shuttle systems (single/double deep)
Horizontal
Automated picking: Aisle-based shuttle systems (single/double deep)
Vertical
Automated picking: Aisle-based shuttle systems (single/double deep)
Diagonal
Automated picking: Aisle-based shuttle systems
Multi-deep storage
- Multi-deep storage lanes are widely used in the food and beverage industry.
- Large volumes of products of limited variety.
- Each lane contains unit loads of the same item (possibly a single batch or production lot).
- In a multi-deep AVS/R system:
- Each tier has an AV1 that consists of:
- Shuttle: Moves along the main cross aisle.
- Satellite: Transports the unit load.
- Each tier has an AV1 that consists of:
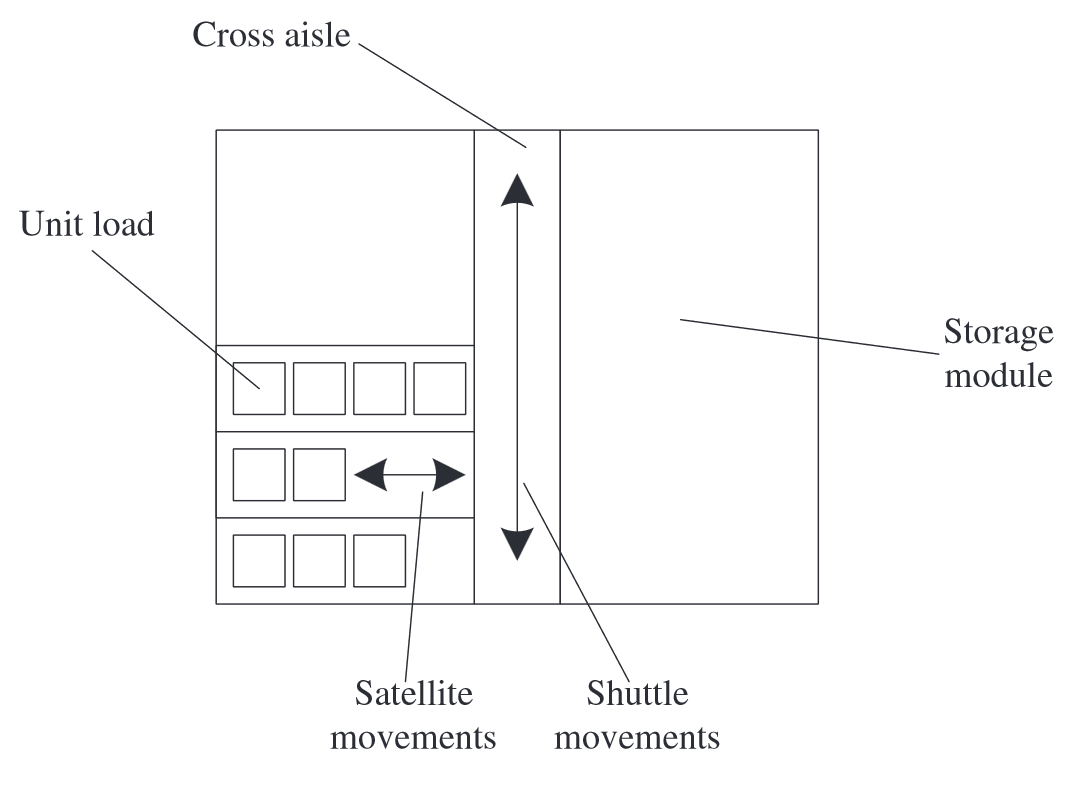
Automated picking: Aisle-based shuttle systems (multi-deep)
Multi-deep shuttle/transfer car
Automated picking
Grid-based shuttle systems
- Automated storage and retrieval system where shuttles move on a grid.
- Storage locations are either
- Dynamic (or puzzle-based system): The stored SKUs move on shuttles to store or retrieve items.
- Static: AVs move the stored SKU.
Automated picking: Grid-based shuttle systems
Dynamic storage (puzzle-based)
- Concept based on Sam Loyd’s 15-tile puzzle.
- A tile represents a load (e.g., a tote, pallet, or container) stored in a grid with one open location.
- Storage density comparison:
- \(k\)-deep aisle-based system: less than or equal to \(2k/(2k + 1)\). Example:
- single-deep = \(2/3\).
- double-deep = \(4/5\).
- \(n\)-cell grid: \((n − 1)/n\).
- \(k\)-deep aisle-based system: less than or equal to \(2k/(2k + 1)\). Example:
- To retrieve a requested unit load, the system repeatedly moves the open locations (called “escorts”) to bring the load to the I/O point.
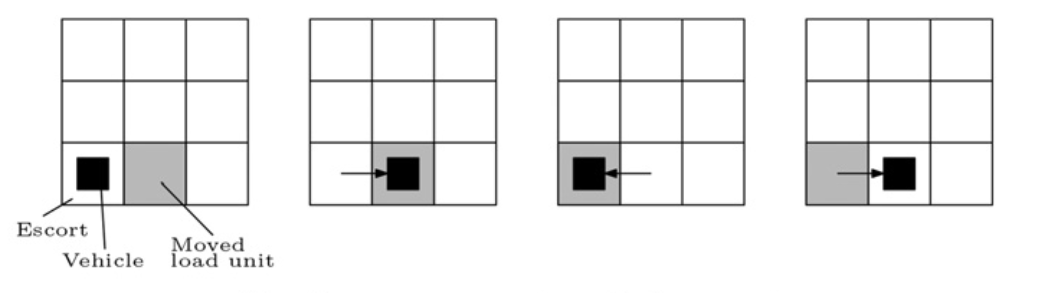
Automated picking: Grid-based shuttle systems (Dynamic storage)
GridStore
- High-density storage system for physical goods
- Rectangular grid of square conveyor modules:
- Modules move items in the four cardinal directions.
- Modules communicate with their neighbors and with the item they carry.
- Rectangular grid of square conveyor modules:
- Throughput can be controlled by:
- Number of rows and columns in the grid.
- Number of empty cells \(k\).
- Number of requested items = work-in-process (WIP).
Automated picking: Grid-based shuttle systems (Dynamic storage)
GridPick
- High-density storage container system:
- No fixed lanes/aisles.
- Open spots on the grid allow items to move during the retrieval process.
- Only containers holding requested items move to the edge of the system (pick face).
- Unlike the GridStore, items do not leave the grid.
Automated picking: Grid-based shuttle systems (Dynamic storage)
Live-Cube
- Multilevel system in which each floor is based on a puzzle-based storage architecture.
- Main components:
- Multiple levels of storage grids.
- Shuttles (can move autonomously and simultaneously).
- Lifts.
- I/O points.
- Shuttles move in \(x\) and \(y\) directions with the load on top of them.
- Loads (individually accessible).
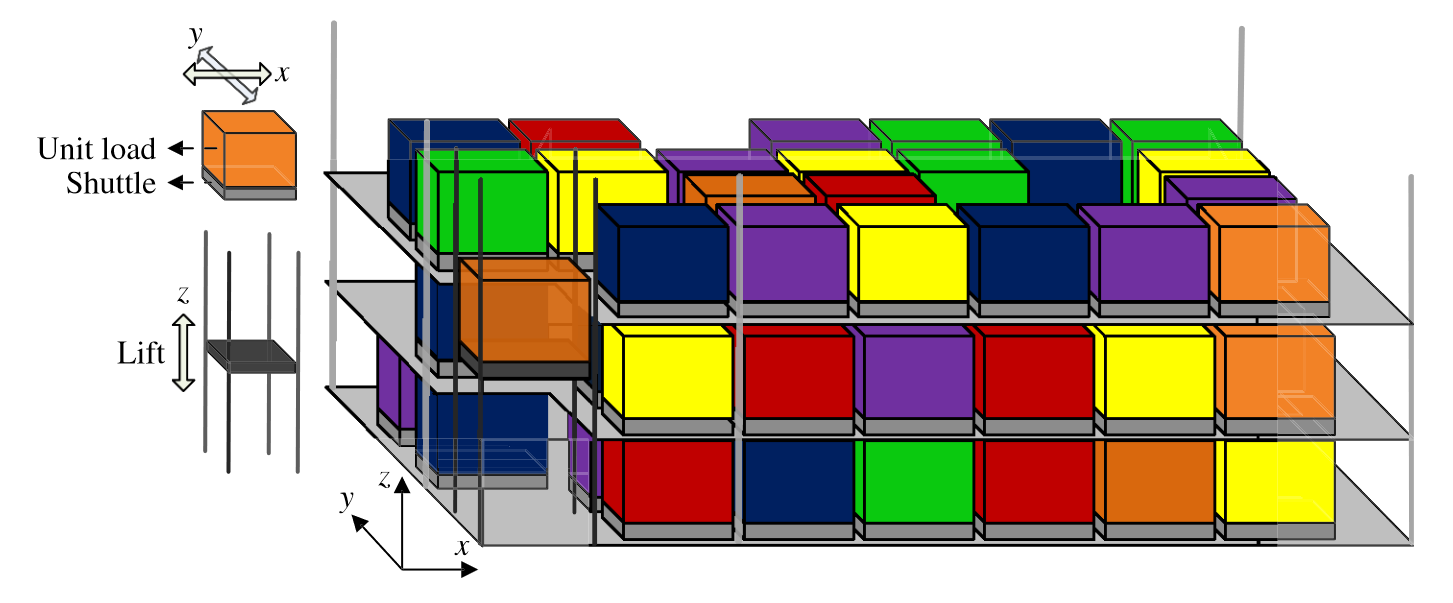
Automated picking: Grid-based shuttle systems (Dynamic storage)
GridFlow
- Instead of conveyors (puzzle-based system), AGVs are used to move the pallets.
- Increased flexibility:
- In a conventional puzzle-based system, the physical layout cannot be changed easily.
- In the GridFlow system, vehicles can form grids of any shape.
Automated picking: Grid-based shuttle systems (Dynamic storage)
GridSort
- Based on the GridFlow system.
- Transport and sort loads using either:
- Modular unit-sized four-directional conveyors (FlexConveyors).
- AGVs.
Automated picking: Grid-based shuttle systems
Static storage
- Grid-based system in which items are stored in a very dense storage stack with a grid on top.
- In each cell of the grid, bins that contain the items are stacked on top of each other and form the storage stacks.
Automated picking: Grid-based shuttle systems (Static storage)
Robotic compact S/R system
- Robot-based compact storage and retrieval (RCSR) system:
- Robots roam on top of the storage block on the grid and
- extract bins from the storage frames (lift);
- transport them to workstations.
- The workstations are located at the lowest level next to the storage stacks.
Automated picking
Automated Guided Vehicle (AGV)
AGVs or autonomous mobile robots (AMRs) support or carry out the picking process.
System configurations:
- Movable rack
- Static rack
Automated picking: Automated Guided Vehicle
Movable Rack
- Internet retailers typically face demand for multi-line, small-quantity orders.
- Travel along the aisles = non-value-added time.
- Bringing the inventory to the picker instead of the picker traveling to the inventory can double picking productivity.
Automated picking: Automated Guided Vehicle (Movable rack)
Robotic mobile fulfillment (RMF) system
- Major components:
- Robotic drive units: robots transporting inventory pods to the workstation for restocking/picking.
- Inventory pods: movable shelf racks with stored products.
- Workstations: ergonomically designed areas where human workers perform pod replenishment, picking, and packing functions.
- Flexible in throughput capacity:
- More robots and pods can be added to the warehouse.
- Important for internet retailers who face volatile demand.
Automated picking: Automated Guided Vehicle
Static Rack
- AGVs are used to pick items at racks:
- Autonomously;
- In parallel with a picker (human-machine interaction).
- Popular in practice because of simplicity and flexibility.
Automated picking: Automated Guided Vehicle (Static rack)
Pick support AGVs/AMRs
- Challenges in retail warehouses:
- Single order requires multiple pick tours (trips between pick locations and the depot).
- Large replenishment orders.
- Orders shipped in multiple roll cages/pallets.
- Pick-support AGV systems minimize the picker travel time to fill large orders:
- AGV automatically follows the picker and transports the roll cages.
- Picker can continue the picking route without returning to the depot.
- Once the roll cage is full:
- The AGV is automatically swapped with a new AGV carrying an empty roll cage.
- AGV automatically transports the full roll cage to the depot.
Automated picking: Automated Guided Vehicle (Static rack)
Pick support AGV example
Automated picking: Automated Guided Vehicle (Static rack)
(Mobile) Pick AGVs
Automated picking
Pick stations (manual vs. robot picking)
- Most automated picking systems are combined with manual piece picking at picking stations.
- Efficient robot picking depends on technologies such as:
- deep learning,
- rapid image processing, and
- appropriate gripper selection.
Human-machine interaction: humans may still be needed to collaborate with robots at picking stations in the coming decades.
Depalletizing system
Autonomous inventory drones
Takeaways
- Why automation?
- Potential savings on space, labor, and operating costs.
- 24/7 availability.
- Scalability and throughput flexibility.
Caveat: ROI is medium- to long-term.
References
Warehousing - M-IEM - Breno A. Beirigo